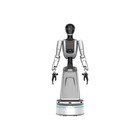
- 1.5 m frame with 16 cm of lift A lifting mechanism extends working height 16 cm above the 1.5 m frame, and gross weight is 96 kg.
- Head and wrist cameras on both builds An Intel RealSense D435 in the head and two RealSense D405 cameras at the wrists are fitted to the Standard and the Flagship alike.
- Hand payload is the main choice The Standard's TH-RH-1-L/R hands are rated for 0.5 kg; the Flagship's high-precision hands are rated for 2 to 3 kg, matching the 2 to 3 kg single-arm load.
- Two onboard computers to choose from The Standard carries a Jetson Orin Nano 8 GB, the Flagship a Jetson AGX Orin 64 GB Developer Kit on an ARM platform for larger perception and planning stacks.
- 21 active degrees of freedom with 18-bit encoders Joints pair harmonic reducers with 18-bit encoders on CAN and EtherCAT, the hands run on a 485 bus, and each hand has six active degrees of freedom.
- Wheeled chassis to 1.5 m/s Maximum navigation speed is 1.5 m/s on high-performance wheels, for structured indoor floors rather than rough terrain.
- Standard interfaces for integration The robot exposes USB, an Ethernet port and a Type-C charging port, with a dual-arm API as the software entry point.


Description
The T170D is the compact wheeled platform of the Ti5 T-series: a 1.5 m frame with a 16 cm lifting mechanism, 96 kg gross, a 1.35 m arm span and 21 active degrees of freedom. Where the T170C trades its reach for a 2 m span and a 41 cm adjustable torso, this one keeps a tighter footprint and a single weight figure.
It is also the better-equipped of the two as delivered. Both builds carry an Intel RealSense D435 head camera and two RealSense D405 wrist cameras, where the T170C fits cameras only to its Flagship. Joints pair harmonic reducers with 18-bit encoders on CAN and EtherCAT, the hands communicate over a 485 bus, each arm is rated for 2 to 3 kg at 0.3 mm repeatability or better, and the wheeled chassis navigates at up to 1.5 m/s. USB, Ethernet and a Type-C charging port handle external connections, and a dual-arm API is the development entry point.
The two builds separate on hands and compute. The Standard pairs TH-RH-1-L/R dexterous hands rated for 0.5 kg with a Jetson Orin Nano 8 GB and has no joint force sensor. The Flagship moves to high-precision hands rated for 2 to 3 kg, adds two six-dimensional force sensors, and runs a Jetson AGX Orin 64 GB Developer Kit on an ARM platform. That makes the choice a practical one: light grasping with compute offloaded to a workstation, or heavier force-controlled manipulation with the perception and planning stack running onboard.
The platform suits dual-arm mobile manipulation work on indoor floors — grasping development, vision-based perception, force-controlled research on the Flagship, and prototyping of commercial handling tasks inside the 2 to 3 kg per-arm envelope. Battery capacity, runtime and ingress protection are confirmed with the quotation.
Key Capabilities
- 1.5 m frame with 16 cm of lift: A lifting mechanism extends working height 16 cm above the 1.5 m frame, and gross weight is 96 kg.
- Head and wrist cameras on both builds: An Intel RealSense D435 in the head and two RealSense D405 cameras at the wrists are fitted to the Standard and the Flagship alike.
- Hand payload is the main choice: The Standard's TH-RH-1-L/R hands are rated for 0.5 kg; the Flagship's high-precision hands are rated for 2 to 3 kg, matching the 2 to 3 kg single-arm load.
- Two onboard computers to choose from: The Standard carries a Jetson Orin Nano 8 GB, the Flagship a Jetson AGX Orin 64 GB Developer Kit on an ARM platform for larger perception and planning stacks.
- 21 active degrees of freedom with 18-bit encoders: Joints pair harmonic reducers with 18-bit encoders on CAN and EtherCAT, the hands run on a 485 bus, and each hand has six active degrees of freedom.
- Wheeled chassis to 1.5 m/s: Maximum navigation speed is 1.5 m/s on high-performance wheels, for structured indoor floors rather than rough terrain.
- Standard interfaces for integration: The robot exposes USB, an Ethernet port and a Type-C charging port, with a dual-arm API as the software entry point.
This model is offered on a quotation basis. Configuration, accessories, integration scope and delivery schedule all change the final figure, so pricing is confirmed per project rather than listed.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Brand | Ti5 Robotics |
|---|---|
| Model | T170D |
| Versions | Standard Model 170D; Flagship Model |
| Configuration | Wheeled dual-arm humanoid with lifting mechanism |
| Total Height | 1.5 m plus 16 cm lifting height |
| Gross Weight | 96 kg |
| Arm Span | 1.35 m |
| Total Active Degrees of Freedom | 21 |
| Single-Arm Load | 2–3 kg |
| Hand Load | Standard: 0.5 kg; Flagship: 2–3 kg |
| Dexterous Hand Model | Standard: TH-RH-1-L/R; Flagship: high-precision dexterous hand |
| Dexterous Hand Degrees of Freedom | 6 active per hand |
| End-Effector Repeatability | ≤0.3 mm |
| Chassis | High-performance wheels |
| Chassis Speed | 1.5 m/s maximum navigation speed |
| Joint Actuator Interface | CAN and EtherCAT |
| Joint Reducer Type | Harmonic |
| Joint Encoder Resolution | 18-bit |
| Joint Force Sensing | Flagship: six-dimensional force sensor × 2; Standard: none |
| Visual Perception | Head Intel RealSense D435 × 1; wrists Intel RealSense D405 × 2 (both versions) |
| Control and Computing | Standard: NVIDIA Jetson Orin Nano 8 GB; Flagship: NVIDIA Jetson AGX Orin 64 GB Developer Kit, ARM platform |
| Software | Dual-arm API |
| Ports | USB, Ethernet port, Type-C charging port |
| Communication | Joints CAN and EtherCAT; hands 485 |
| Materials | Structure aluminium alloy and similar; appearance ABS and similar |
| Battery Capacity and Runtime | Confirm at quote |
| Ingress Protection | Confirm at quote |
| Price | Quotation only |
Industries
Frequently Asked Questions
The T170D has a fixed 1.5 m frame with a 16 cm lift against the T170C's 1.28 to 1.69 m adjustable torso, a 1.35 m arm span against 2 m, 21 degrees of freedom against 22, 18-bit joint encoders against 16/18-bit, and a 1.5 m/s chassis against 2.0 m/s. It also fits head and wrist cameras to both builds, where the T170C has cameras and onboard compute on its Flagship only.
Hands, force sensing and compute. The Standard has TH-RH-1-L/R hands rated for 0.5 kg, no joint force sensor and a Jetson Orin Nano 8 GB. The Flagship has high-precision hands rated for 2 to 3 kg, two six-dimensional force sensors and a Jetson AGX Orin 64 GB Developer Kit on an ARM platform. The chassis, arms, cameras and frame are the same.
Each arm is rated for 2 to 3 kg with end-effector repeatability of 0.3 mm or better. Hand load depends on the build: 0.5 kg on the Standard and 2 to 3 kg on the Flagship.
No. It uses high-performance wheels with a maximum navigation speed of 1.5 m/s, plus a 16 cm lifting mechanism that raises working height above the 1.5 m frame.
Both builds carry one Intel RealSense D435 head camera and two RealSense D405 wrist cameras. External connections are USB, an Ethernet port and a Type-C charging port, with joints on CAN and EtherCAT and the hands on a 485 bus.
It is offered by quotation. Version, configuration, quantity and delivery are confirmed per project, and the price is set in the quotation.
Recently Viewed
You haven't viewed any products yet.