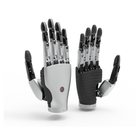
- Six independent actuators Each finger moves on its own and the thumb moves in two directions, giving the opposition that grasping, pinching and holding depend on.
- Human-hand size at 480 g An 80 mm palm, a 132 mm maximum width and a 205 mm length including 97 mm fingers keep the hand close to human scale.
- 40 N closing grip Fingertips push with 10 N, the thumb with 12 N, the closing grip reaches 40 N and palm traction 80 N.
- Force subdivision by torque control Ti5's torque control algorithm divides commanded force into fine steps for fragile, soft or irregular objects.
- Coordinated multi-joint control Several joints move together on one command, so natural gestures need no joint-by-joint programming.
- 7.4 V, 3 A peak The hand draws 0.1 A at rest and up to 3 A from a 7.4 V supply, which suits battery-powered robots.
- Made to pair with Ti5 arms Ti5 designed the hand to work with its own ARM and EBLM series collaborative arms.


Description
The Ti5 Intelligent Bionic Hand is Ti5 Robotics' five-finger bionic robotic hand from its Cool Hand line, built as a precision end-effector for humanoid robots, collaborative arms and manipulation research. Six independent actuators move the fingers, and the thumb moves in two directions, which gives the opposition that grasping, pinching and holding depend on. The whole hand weighs 480 g.
It is sized close to a human hand: an 80 mm palm, a 132 mm maximum width, a 205 mm total length including 97 mm fingers, and 132 mm from the thumb base to the bottom of the palm. Fingertips push with 10 N, fingers press sideways with 8 N, the thumb with 12 N, the closing grip reaches 40 N and palm traction 80 N, so the same hand covers a light pinch and a firm power grip.
Ti5's torque control algorithm divides commanded force into fine steps for fragile, soft or irregular objects, and coordinated multi-joint control moves several fingers together on one command, so natural gestures need no joint-by-joint programming. Ti5's own motion-sensing control technology drives both. Power is modest — 7.4 V, 0.1 A at rest and up to 3 A at maximum — which suits battery-powered platforms as readily as a bench supply.
Ti5 builds the hand for industrial production, research and education, commercial service and medical rehabilitation, and designed it to work with its ARM and EBLM series collaborative arms. The communication interface, hand side and mounting for other arms are confirmed with the quotation. Compare it with the rest of our dexterous robotic hands.
Key Capabilities
- Six independent actuators: Each finger moves on its own and the thumb moves in two directions, giving the opposition that grasping, pinching and holding depend on.
- Human-hand size at 480 g: An 80 mm palm, a 132 mm maximum width and a 205 mm length including 97 mm fingers keep the hand close to human scale.
- 40 N closing grip: Fingertips push with 10 N, the thumb with 12 N, the closing grip reaches 40 N and palm traction 80 N.
- Force subdivision by torque control: Ti5's torque control algorithm divides commanded force into fine steps for fragile, soft or irregular objects.
- Coordinated multi-joint control: Several joints move together on one command, so natural gestures need no joint-by-joint programming.
- 7.4 V, 3 A peak: The hand draws 0.1 A at rest and up to 3 A from a 7.4 V supply, which suits battery-powered robots.
- Made to pair with Ti5 arms: Ti5 designed the hand to work with its own ARM and EBLM series collaborative arms.
This model is offered on a quotation basis. Configuration, accessories, integration scope and delivery schedule all change the final figure, so pricing is confirmed per project rather than listed.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Brand | Ti5 Robotics |
|---|---|
| Model | Intelligent Bionic Hand (Cool Hand series) |
| Fingers | 5 |
| Degrees of freedom | 6 |
| Actuation | 6 internal actuators; each finger moves independently, the thumb in two directions |
| Weight | 480 g |
| Palm width | 80 mm |
| Maximum hand width | 132 mm |
| Total length including fingers | 205 mm |
| Finger length | 97 mm |
| Thumb base to bottom of palm | 132 mm |
| Fingertip force | 10 N |
| Lateral finger force | 8 N |
| Thumb force | 12 N |
| Closing grip force | 40 N |
| Palm traction force | 80 N |
| Operating voltage | 7.4 V |
| Static current | 0.1 A |
| Maximum current | 3 A |
| Control | Torque control algorithm for force subdivision; coordinated multi-joint control; motion-sensing control |
| Grasp actions | Grasp, pinch, hold |
| Matching arms | Ti5 ARM and EBLM series collaborative arms |
| Communication interface | Confirm at quote |
| Mounting interface | Confirm at quote |
| Hand side | Confirm at quote |
Industries
Frequently Asked Questions
It is offered by quotation — configuration, quantity and delivery are confirmed per project.
Six, from six internal actuators. Each finger moves independently and the thumb moves in two directions.
Fingertip force is 10 N, lateral finger force 8 N, thumb force 12 N, closing grip 40 N and palm traction 80 N.
It weighs 480 g, with an 80 mm palm, a 132 mm maximum width and a 205 mm total length including the 97 mm fingers.
It runs at 7.4 V, drawing 0.1 A at rest and up to 3 A at maximum, which suits battery-powered humanoids as well as bench setups.
Ti5 designed it to work with its ARM and EBLM series collaborative arms. The communication interface, hand side and mounting for your arm are confirmed with the quotation.
Recently Viewed
You haven't viewed any products yet.