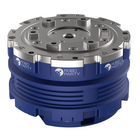
- 44 N·m rated, 160 N·m peak The family's headline peak torque belongs to this module and to short-duration conditions, not to continuous operation.
- 80 rpm rated through a 22:1 reduction Peak speed is 130 rpm and no-load speed 141 rpm (±10 %), each separate from the rated figure.
- 100 mm diameter, 1,197 g The axial dimension is 61.7 mm (±0.5) with a 7.5 mm hollow bore, the largest envelope in the family.
- 370 W rated power Backlash is 11.4 arcmin and motor rotational inertia at 60.6 kg·mm² for simulation inputs.
- 11 A rated, 55 A peak at 48 V Line resistance of 0.179 Ω, inductance of 0.244 mH, a 10.8 V/krpm back-EMF constant and fourteen pole pairs define the electrical envelope.
- Dual encoders over CAN FD or EtherCAT Resolution is 17 bit and 19 bit, designated inner ring and outer ring on this model; confirm the assignment against the drawing.
- Hollow cable routing and clamp fixation Hardware drawings and driver source code are available for the family, and the hollow dimension is specific to this module.

Description
The ROMOMO 10062 is the largest module in RoboParty's joint-module family and the module behind the 160 N·m peak torque of its humanoids. Rated torque is 44 N·m (±5 %) at 80 rpm through a 22:1 reduction, with a 130 rpm peak speed, a measured prototype mass of 1,197 g and an envelope of 100 mm outer diameter by 61.7 mm (±0.5) axially with a 7.5 mm hollow bore.
The 160 N·m headline belongs to this model and to short-duration conditions only — it is not a continuous rating, and it is not the torque of every joint in a robot that uses the family. Sustained work is sized from the rated column with a defined duty cycle. Further motion data: no-load speed 141 rpm (±10 %), rated power 370 W (±5 %) and backlash of 11.4 arcmin.
Electrically it draws 11 A (±5 %) rated and 55 A (±10 %) peak from 48 V, with 0.179 Ω line resistance at 20 °C, 0.244 mH line inductance, a 10.8 V/krpm back-EMF constant and fourteen pole pairs — a much heavier supply than the 2 A rated of the small 6562. Feedback is dual encoders at 17 bit and 19 bit, designated inner ring and outer ring on this model, over CAN FD or EtherCAT. Motor rotational inertia is 60.6 kg·mm². The torque constant is 0.163 N·m/A; confirm its reference convention with the quotation before using it in a current-to-torque calculation.
ROMOMO modules are RoboParty's own actuators, the same family used in its ROBOTO 01 humanoids. The family is built for clamp fixation and hollow cable routing through the output, with access to hardware drawings and driver source code. Hollow dimensions and mounting details vary by model and are confirmed against this module's drawing. Insulation is class F (155 °C), which is an insulation rating rather than an ambient operating temperature; ingress protection and any certified safety function are confirmed with the quotation.
Key Capabilities
- 44 N·m rated, 160 N·m peak: The family's headline peak torque belongs to this module and to short-duration conditions, not to continuous operation.
- 80 rpm rated through a 22:1 reduction: Peak speed is 130 rpm and no-load speed 141 rpm (±10 %), each separate from the rated figure.
- 100 mm diameter, 1,197 g: The axial dimension is 61.7 mm (±0.5) with a 7.5 mm hollow bore, the largest envelope in the family.
- 370 W rated power: Backlash is 11.4 arcmin and motor rotational inertia at 60.6 kg·mm² for simulation inputs.
- 11 A rated, 55 A peak at 48 V: Line resistance of 0.179 Ω, inductance of 0.244 mH, a 10.8 V/krpm back-EMF constant and fourteen pole pairs define the electrical envelope.
- Dual encoders over CAN FD or EtherCAT: Resolution is 17 bit and 19 bit, designated inner ring and outer ring on this model; confirm the assignment against the drawing.
- Hollow cable routing and clamp fixation: Hardware drawings and driver source code are available for the family, and the hollow dimension is specific to this module.
This model is offered on a quotation basis. Configuration, accessories, integration scope and delivery schedule all change the final figure, so pricing is confirmed per project rather than listed.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Brand | RoboParty |
|---|---|
| Manufacturer | RoboParty |
| Model | ROMOMO 10062 |
| Product Type | Robot joint module (integrated actuator) |
| Rated Torque | 44 N·m ±5 % |
| Peak Torque | 160 N·m (short-duration) |
| Rated Speed | 80 rpm |
| Peak Speed | 130 rpm |
| No-Load Speed | 141 rpm ±10 % |
| Reduction Ratio | 22:1 |
| Rated Power | 370 W ±5 % |
| Backlash | 11.4 arcmin |
| Mass | 1,197 g measured prototype mass (family specification limit under 1,260 g) |
| Rated Voltage | 48 V |
| Rated Current | 11 A ±5 % |
| Peak Current | 55 A ±10 % |
| Line Resistance (20 °C) | 0.179 Ω ±5 % |
| Line Inductance | 0.244 mH ±10 % |
| Back-EMF Constant | 10.8 V/krpm |
| Pole Pairs | 14 |
| Torque Constant | 0.163 N·m/A (reference convention confirmed at quote) |
| Communication | CAN FD / EtherCAT |
| Feedback | Dual encoders, 17 bit inner ring / 19 bit outer ring |
| Outer Diameter | 100 mm |
| Axial Dimension | 61.7 mm ±0.5 |
| Hollow Diameter | 7.5 mm |
| Motor Rotational Inertia | 60.6 kg·mm² |
| Insulation Class | F (155 °C) — an insulation rating, not an operating temperature |
| Structure | Two-stage planetary, inner-rotor |
| Ingress Protection | Confirm at quote |
| Ambient Operating Temperature | Confirm at quote |
| Mounting Pattern | Confirm at quote |
| Price | Quotation only |
Industries
Frequently Asked Questions
It is the largest integrated joint module in RoboParty's ROMOMO family, rated at 44 N·m with 5 % tolerance, 160 N·m peak, 80 rpm rated speed and a 22:1 reduction.
No. RoboParty identifies peak parameters as short-duration conditions, so sustained duty is sized from the 44 N·m rated figure. The 160 N·m headline also belongs to this module specifically, not to every joint in a robot built from the family.
It is the heavy one: 44 N·m rated against the 8462's 14 N·m and the 6562's 10 N·m, 100 mm outer diameter against the 6562's 65 mm, and 1,197 g against 779.4 g and 533.1 g. It also draws 11 A rated where the 6562 draws 2 A.
Dual encoders at 17 bit and 19 bit over CAN FD or EtherCAT. The two rings are designated inner and outer on this model, so check the assignment against the drawing before a more specific interface interpretation.
Confirm the basis first. It is 0.163 N·m/A for this module against 2.37 N·m/A on the smaller 6562, so the reference point and measurement convention behind each figure are confirmed with the quotation before either is used in a motor model.
It is offered by quotation — the exact model, control interface, supplied wiring, documentation revision and intended duty are confirmed per project.
Recently Viewed
You haven't viewed any products yet.