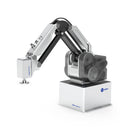
- 190 × 190 mm footprint The base is smaller than a sheet of A4 paper and the whole arm weighs 8 kg, so it sits on a bench rather than needing a cell.
- Controller and servo drive inside the arm There is no separate control cabinet to house, which is what makes the desktop footprint real rather than nominal.
- ±0.05 mm repeatability over 440 mm The four-axis arm repeats to five hundredths of a millimetre within a 440 mm working radius.
- 300°/s per joint Maximum joint speed is 300°/s on every axis, with J1 at ±160° and J4 at ±360°.
- Drag-to-teach and collision detection An operator can move the arm by hand to set a point instead of entering coordinates, and collision detection is built in.
- Graphical, script and SDK programming DobotStudio Pro and CRStudio provide Blockly blocks and Lua scripting, with an SDK covering Java, C++, C#, Python, ROS, MATLAB, LabVIEW and Android.
- Ordinary single-phase supply It runs from 100–240 V AC at 50/60 Hz on a 48 V nominal bus, within an ambient range of 0 to 40 °C.

Description
The MG400 is a four-axis desktop arm that stands on a 190 × 190 mm base — smaller than a sheet of A4 paper — and weighs 8 kg, so one person can lift it onto a bench and bolt it down. It handles 500 g rated, 750 g at maximum, within a 440 mm reach, and repeats to ±0.05 mm.
Its controller and servo drives are inside the arm itself. There is no separate control cabinet to find space for, which is the practical reason it fits on a workbench, in a classroom or inside a small machine enclosure where a cabinet would not go. It runs from ordinary mains at 100–240 V AC, 50/60 Hz, on a 48 V nominal bus.
Programming has several entry points. DobotStudio Pro runs on a PC and CRStudio on Android and iOS; Blockly gives a block-based graphical route, Lua a scripting route, and an SDK covers Java, C++, C#, Python, ROS, MATLAB, LabVIEW and Android. Drag-to-teach lets an operator move the arm by hand to set a point rather than type coordinates, and collision detection is built in.
Each joint moves at up to 300°/s, with J1 and J4 at ±160° and ±360° and J2 and J3 covering −25° to 85° and −25° to 105°. The arm is rated IP20 and works from 0 to 40 °C, so it belongs in a clean, dry indoor setting rather than a washdown area. Its rated power is 150 W, and the rating that applies to your unit is confirmed in writing with the order.
Key Capabilities
- 190 × 190 mm footprint: The base is smaller than a sheet of A4 paper and the whole arm weighs 8 kg, so it sits on a bench rather than needing a cell.
- Controller and servo drive inside the arm: There is no separate control cabinet to house, which is what makes the desktop footprint real rather than nominal.
- ±0.05 mm repeatability over 440 mm: The four-axis arm repeats to five hundredths of a millimetre within a 440 mm working radius.
- 300°/s per joint: Maximum joint speed is 300°/s on every axis, with J1 at ±160° and J4 at ±360°.
- Drag-to-teach and collision detection: An operator can move the arm by hand to set a point instead of entering coordinates, and collision detection is built in.
- Graphical, script and SDK programming: DobotStudio Pro and CRStudio provide Blockly blocks and Lua scripting, with an SDK covering Java, C++, C#, Python, ROS, MATLAB, LabVIEW and Android.
- Ordinary single-phase supply: It runs from 100–240 V AC at 50/60 Hz on a 48 V nominal bus, within an ambient range of 0 to 40 °C.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Brand | Dobot |
|---|---|
| Model | MG400 |
| Product Type | Four-axis desktop robotic arm |
| Degrees of Freedom | 4 |
| Payload | 500 g rated, 750 g maximum |
| Reach | 440 mm |
| Repeatability | ±0.05 mm |
| Joint Ranges | J1 ±160°; J2 −25° to 85°; J3 −25° to 105°; J4 ±360° |
| Maximum Joint Speed | 300°/s per joint |
| Weight | 8 kg |
| Base Size | 190 × 190 mm |
| Power Supply | 100–240 V AC, 50/60 Hz |
| Nominal Voltage | 48 V |
| Rated Power | 150 W (confirm at quote) |
| Controller | Integrated controller and servo drive inside the arm |
| Communication | TCP/IP, Modbus TCP |
| Ingress Protection | IP20 |
| Installation | Desktop / counter mounting |
| Working Environment | 0 to 40 °C |
| Software | DobotStudio Pro (PC) and CRStudio (Android, iOS); Blockly graphical programming; Lua scripting |
| SDK | Java, C++, C#, Python, ROS, MATLAB, LabVIEW, Android |
| Teaching | Drag-to-teach |
| Safety | Collision detection |
| End Effector | Confirm at quote |
Industries
Frequently Asked Questions
A 190 × 190 mm base, smaller than a sheet of A4 paper, with a 440 mm working radius around it. The controller and servo drives are inside the arm, so no separate cabinet has to be housed.
500 g rated and 750 g at maximum. It is a light-duty arm for small-part handling, dispensing, testing and teaching rather than for heavier assembly.
DobotStudio Pro on a PC or CRStudio on Android and iOS, with Blockly blocks for graphical programming and Lua for scripting. An SDK covers Java, C++, C#, Python, ROS, MATLAB, LabVIEW and Android, and drag-to-teach sets points by hand.
Indoors on a bench or counter. The arm is rated IP20 and specified for 0 to 40 °C, so it is not suited to washdown, dusty or outdoor positions.
Rated power is 150 W at a 48 V nominal bus from a 100–240 V AC 50/60 Hz supply. The rating for your unit is confirmed in writing with the order.
The Dobot MG400 Desktop Robotic Arm is priced at Rs. 195,600 in your market.
Recently Viewed
You haven't viewed any products yet.